Verder naar inhoud

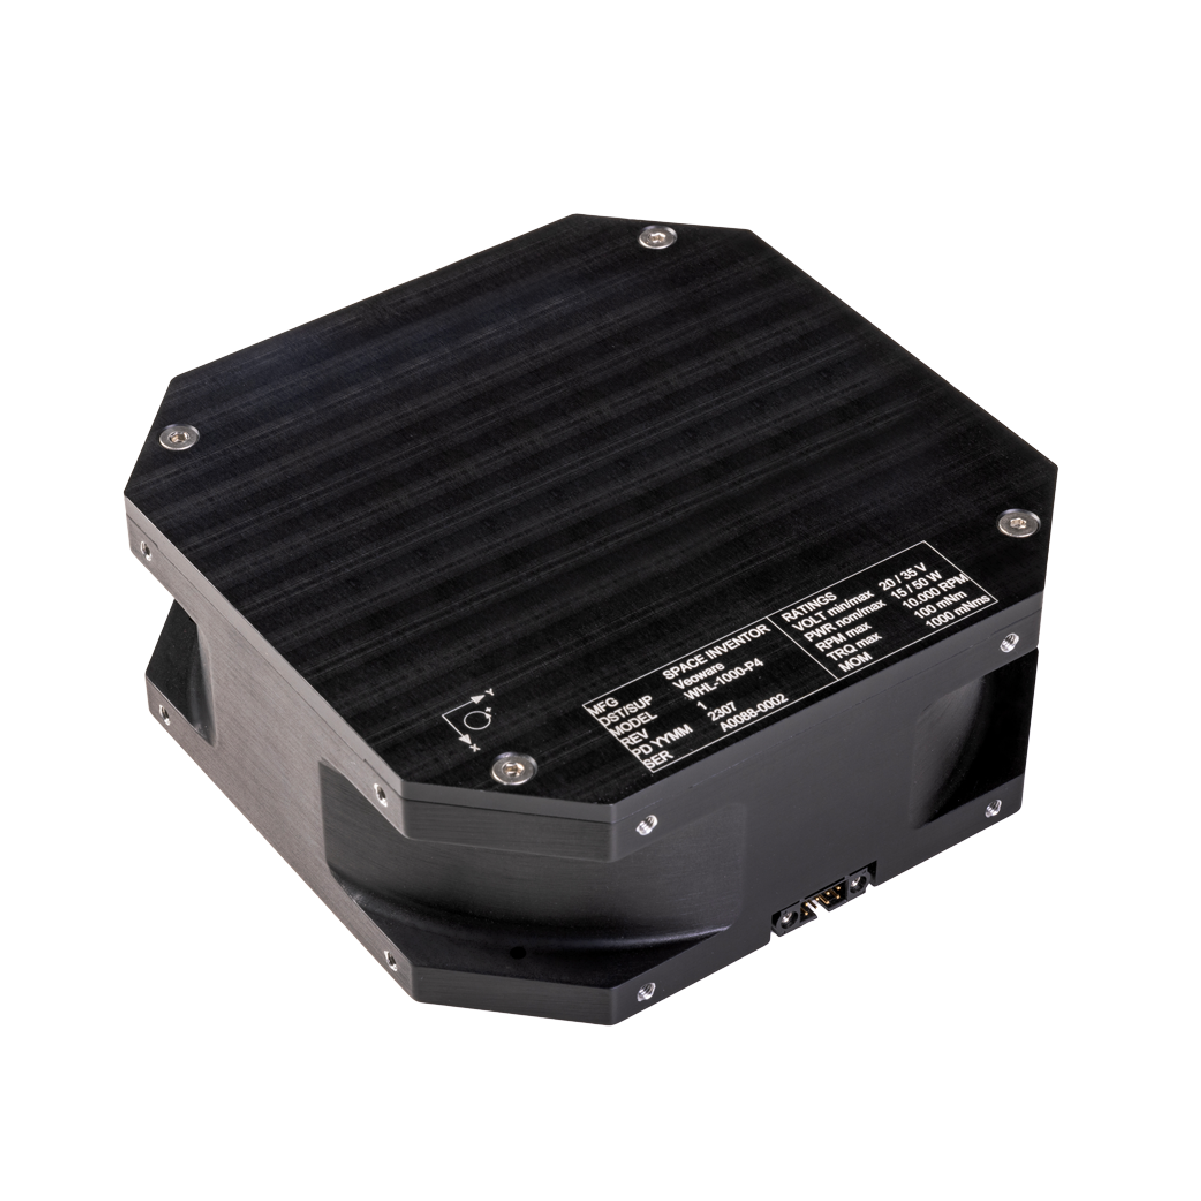
Reaction Wheels

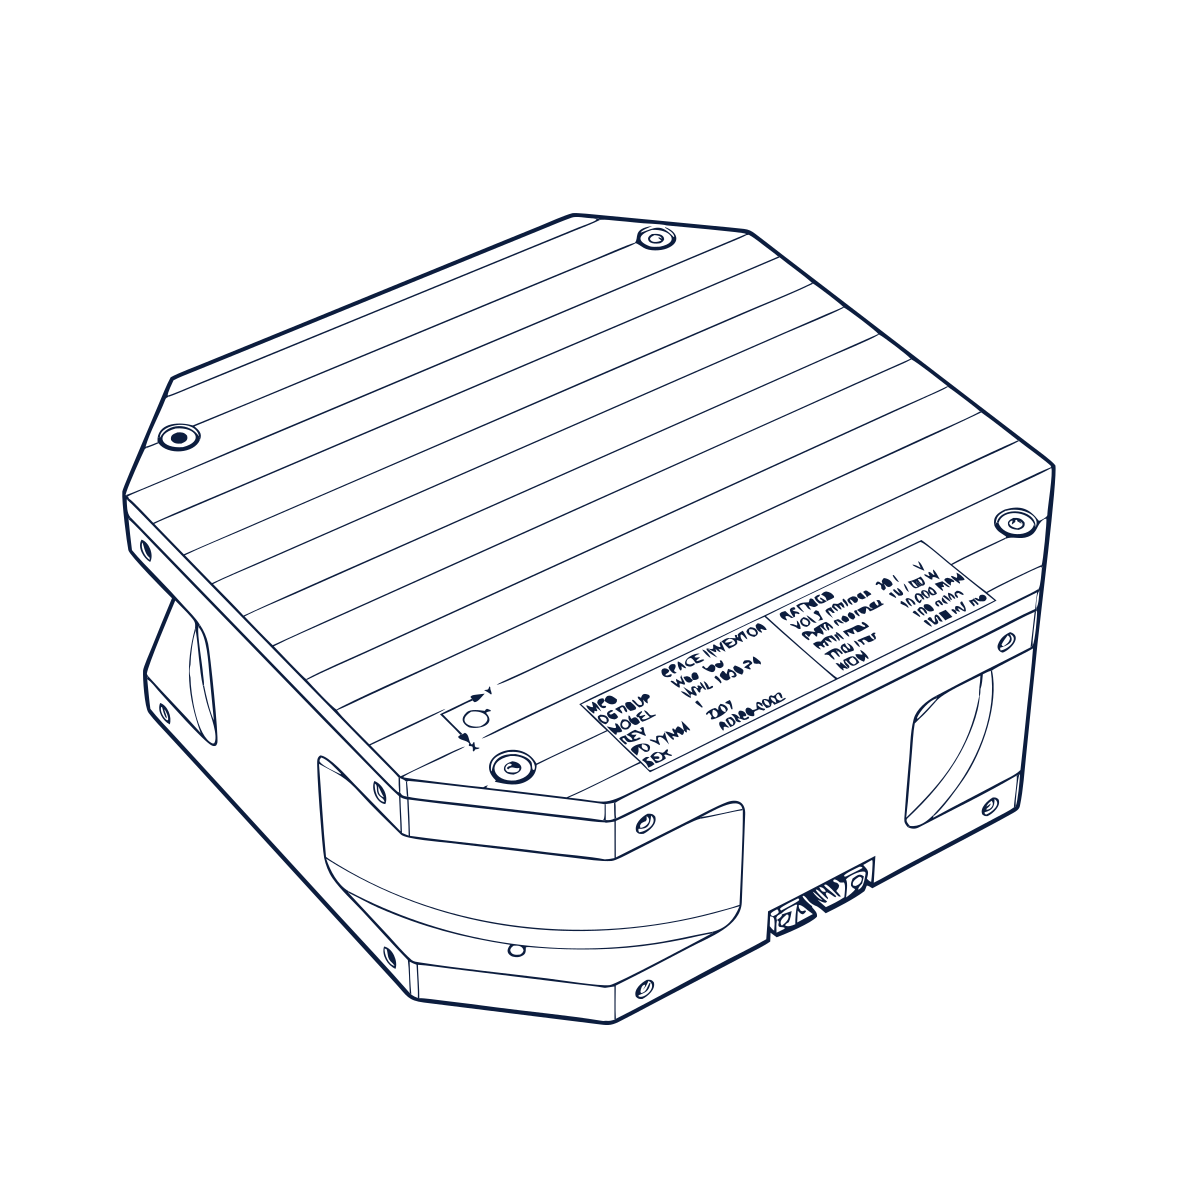
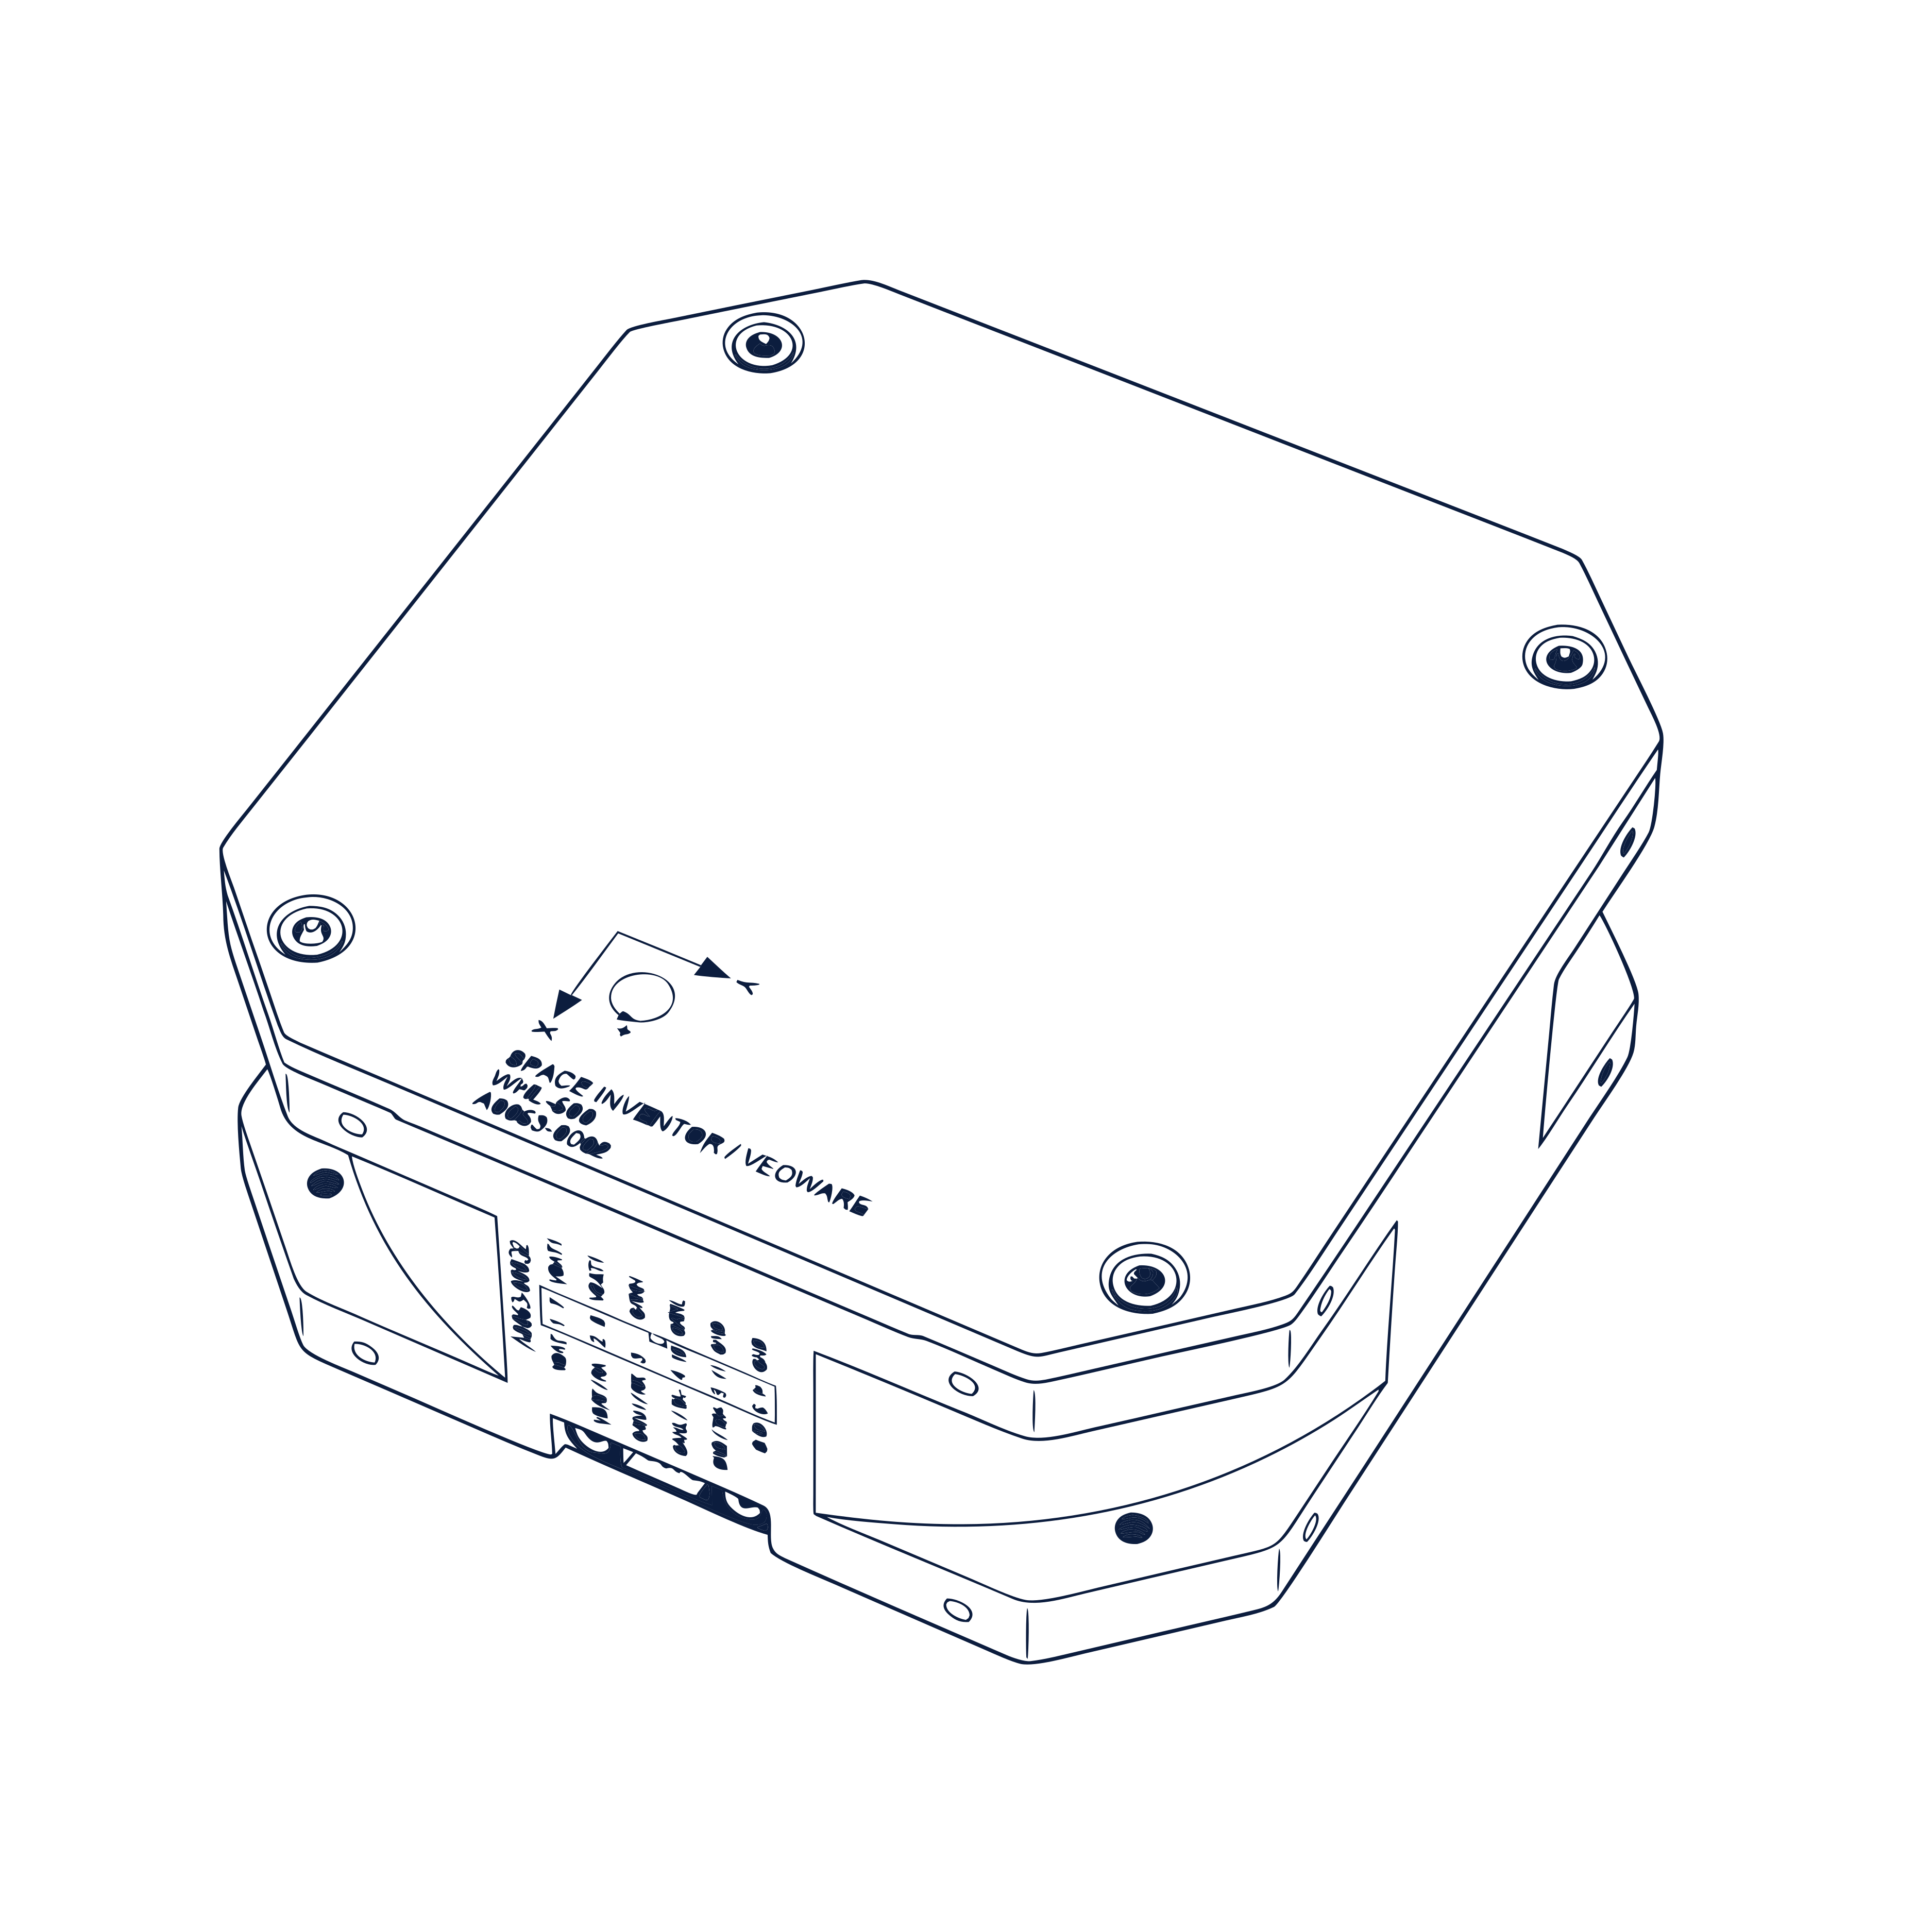
blueprint WHL-500 WHL-500

Technical Specifications

WHL-1000

WHL-1000
Momentum
1 Nms
Output Torque
100 mNm
Volume
109 x 109 xx 42.5 mm³
Mass
1.2 kg
Operating Voltage Range
9 to 33.6 V
Interface
CAN - UART
Momentum (4x WHL)*
1.78 Nms
Torque (4x WHL)*
up to 180 mNm

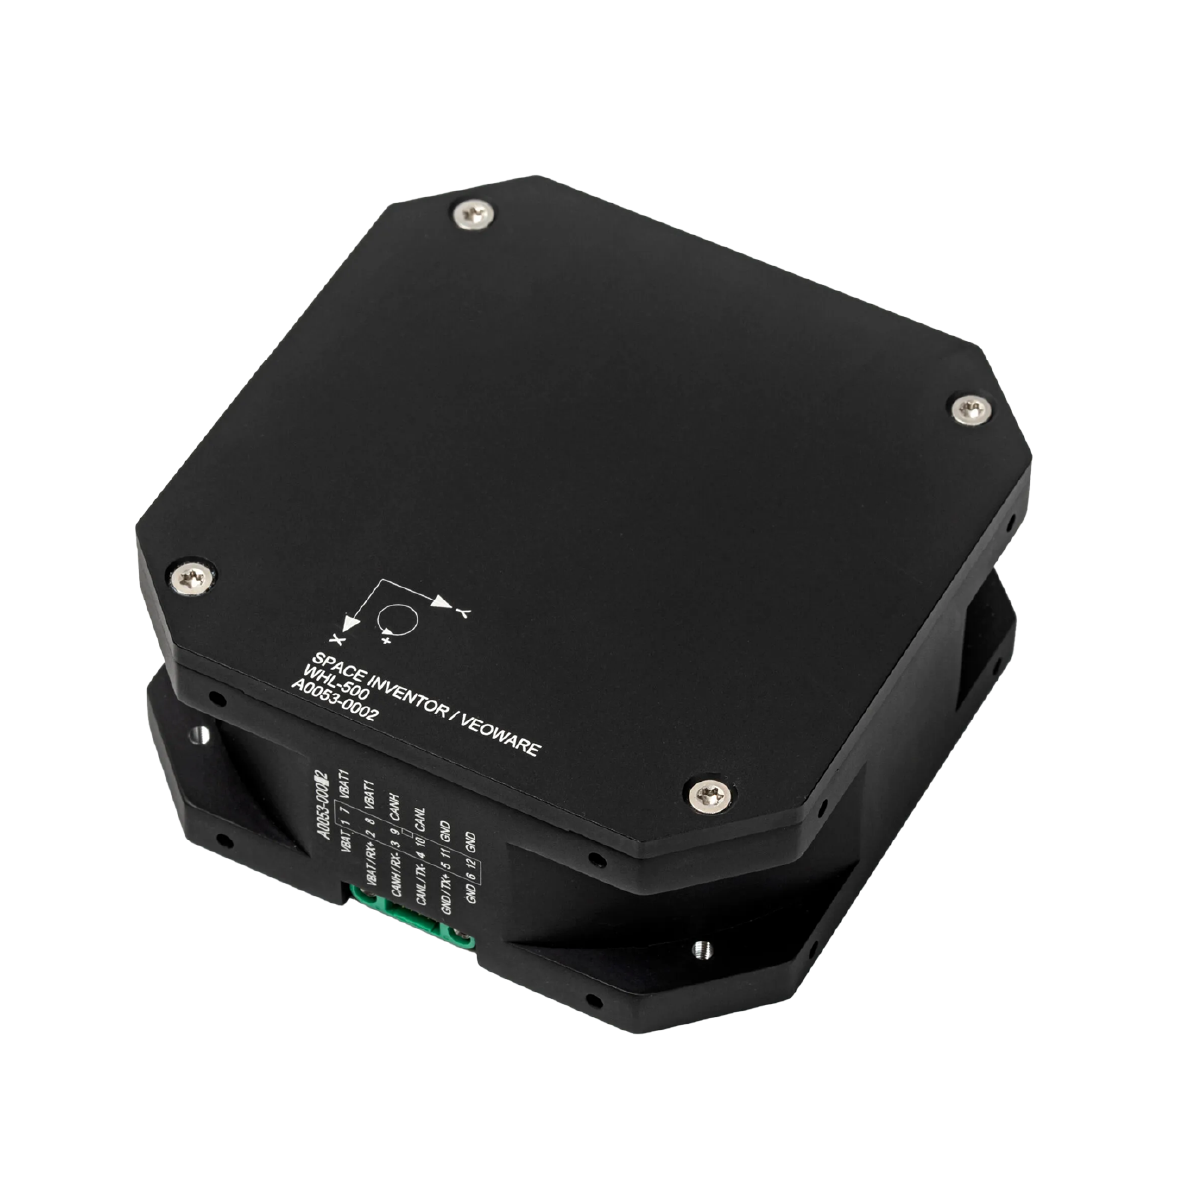
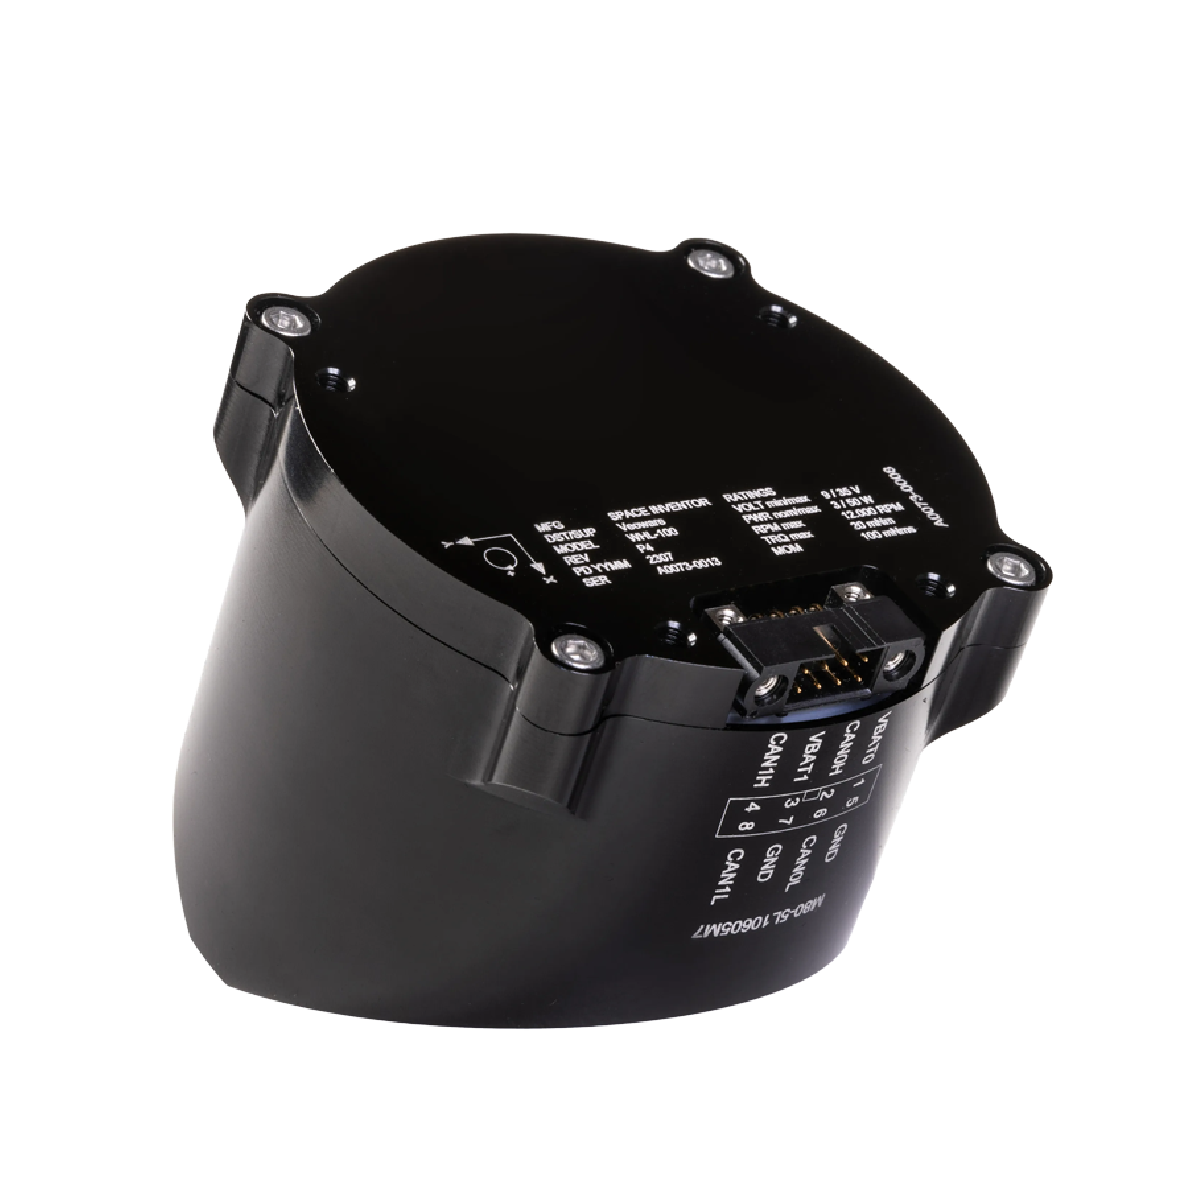
WHL-500

WHL-500
Momentum
500 mNms
Output Torque
100 mNm
Volume
97 x 97 x 40 mm³
Mass
0.8 kg
Operating Voltage Range
20 - 35 V
Interface
CAN
Momentum (4x WHL)*
890 Nms
Torque (4x WHL)*
up to 180 mNm

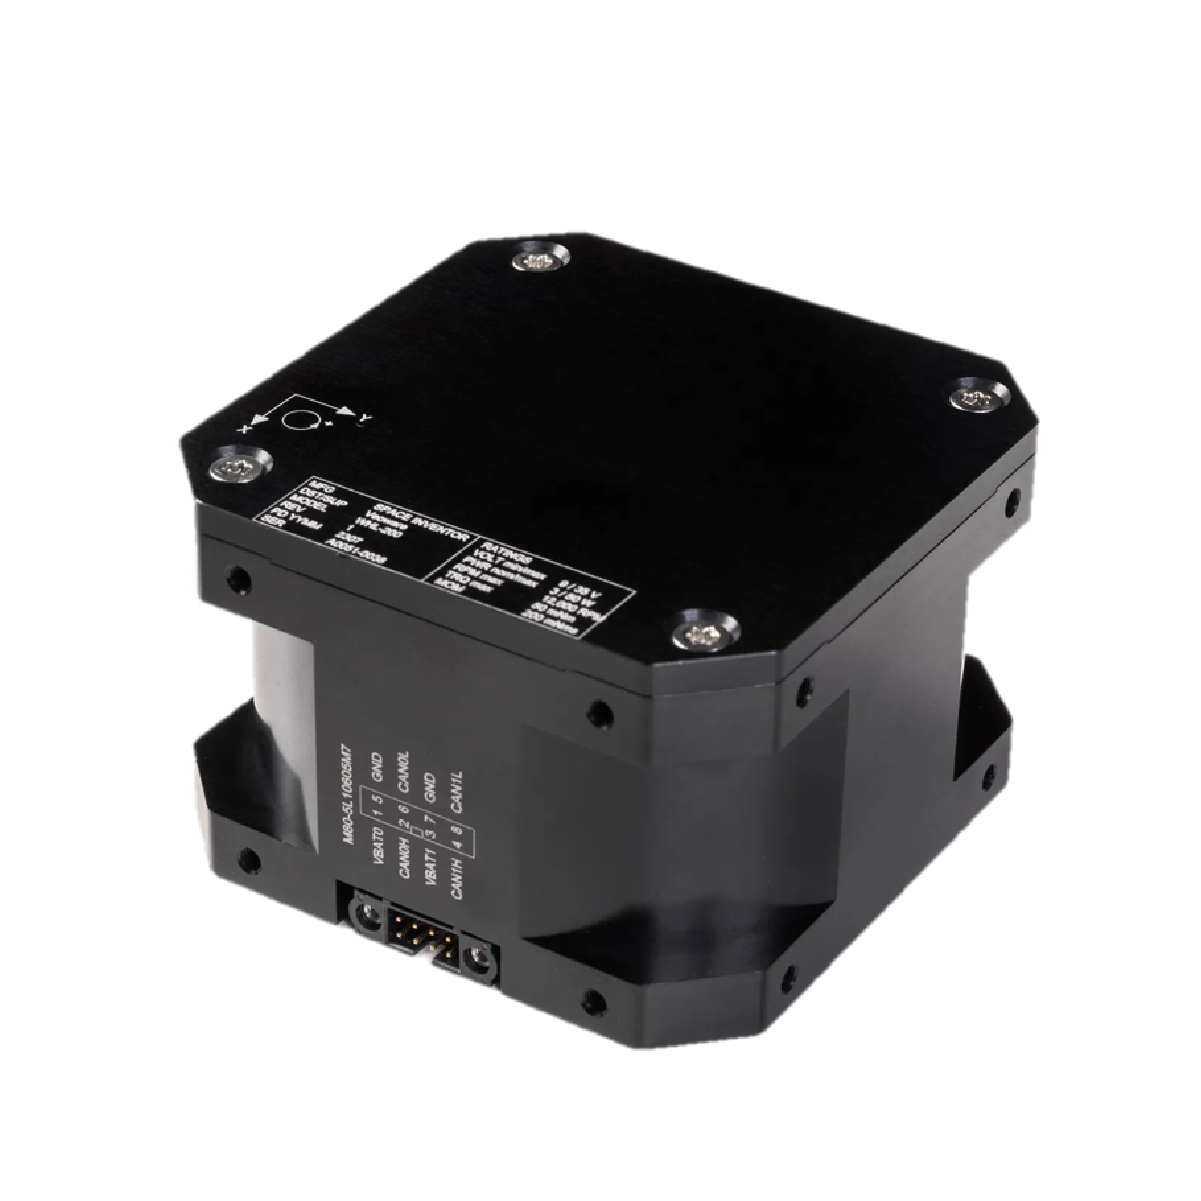
WHL-200

WHL-200
Momentum
200 mNms
Output Torque
25 mNm
Volume
70 x 70 x 45 mm³
Mass
430 g
Operating Voltage Range
9 - 33.6 V
Interface
CAN
Momentum (4x WHL)*
356 Nms
Torque (4x WHL)*
up to 45 mNm

WHL-100

WHL-100
Momentum
100 mNms
Output Torque
20 mNm
Volume
60 x 60 x 45 mm³
Mass
0.35 kg
Operating Voltage Range
9 - 33.6 V
Interface
CAN
Momentum (4x WHL)*
890 Nms
Torque (4x WHL)*
up to 36 mNm

Scan wider. Slew between every target.

Pyramid Mini CMG configuration gives a 500 kg class imaging satellite the torque to re-orient several degrees per second, capturing target after target without excessive wait time waiting for the spacecraft.

See use case

Multi-Strip Imaging

A satellite equipped with a cluster of control-moment gyroscopes provides the necessary control authority to reorient the spacecraft between target acquisition and collection. A satellite of 100 kgm^2 of inertia is being considered for the following use case,

Discover use case

Get the content

Tell us where to send the requested content and our team will follow up.

Thanks, your request was sent. We will follow up shortly.